Robbyant unveils LingBot-Touch tactile foundation model
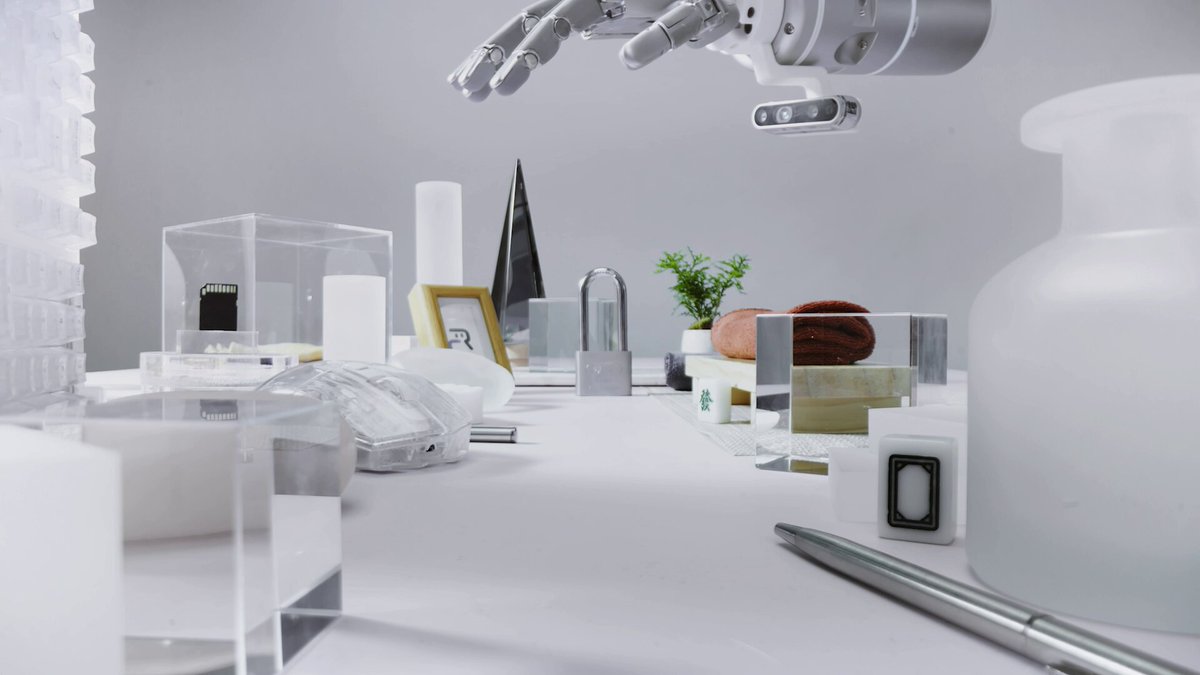
What changes when robots can feel, not just see? 🤖✋ Robbyant introduces LingBot-Touch, its open-source tactile foundation model for dexterous manipulation, pretrained on nearly 5,000 hours of real tactile data. Through unified heterogeneous tactile modeling, LingBot-Touch supports transfer across sensors, dexterous hands, tasks and action models. A demo clip accompanies the post.
 ▶
✓ Verified
2026-11-09