Company · INDEMIND 2 items
← Supply Chain MapCompany Profile

One-line positioning
INDEMIND is a Beijing supplier of robot "navigation brains", visual-SLAM-based navigation modules that turn "don't bump, plan paths, auto-dock" into off-the-shelf components for robot OEMs.
Key facts
Beijing-based (founded ~2017; domain status currently anomalous, info per public industry reports). Products: VSLAM visual navigation, LiDAR+vision fusion, active obstacle avoidance, semantic recognition (DONUT line). Sells modules + SDK + algorithm licensing to sweeper/commercial-cleaner/service-robot makers. Early-stage funding (per public reports).
Products & tech
Camera-only VSLAM (no LiDAR needed), fusion schemes, perception modules. Cost and deployment advantages over LiDAR-only navigation; robustness in cluttered homes (cables, glass, dynamic obstacles).
Market position
The visual-SLAM counterpart to SLAMTEC's LiDAR route in China's navigation-module market. Investor watchpoint: OEM self-supply substitution risk.
Products
1/2 items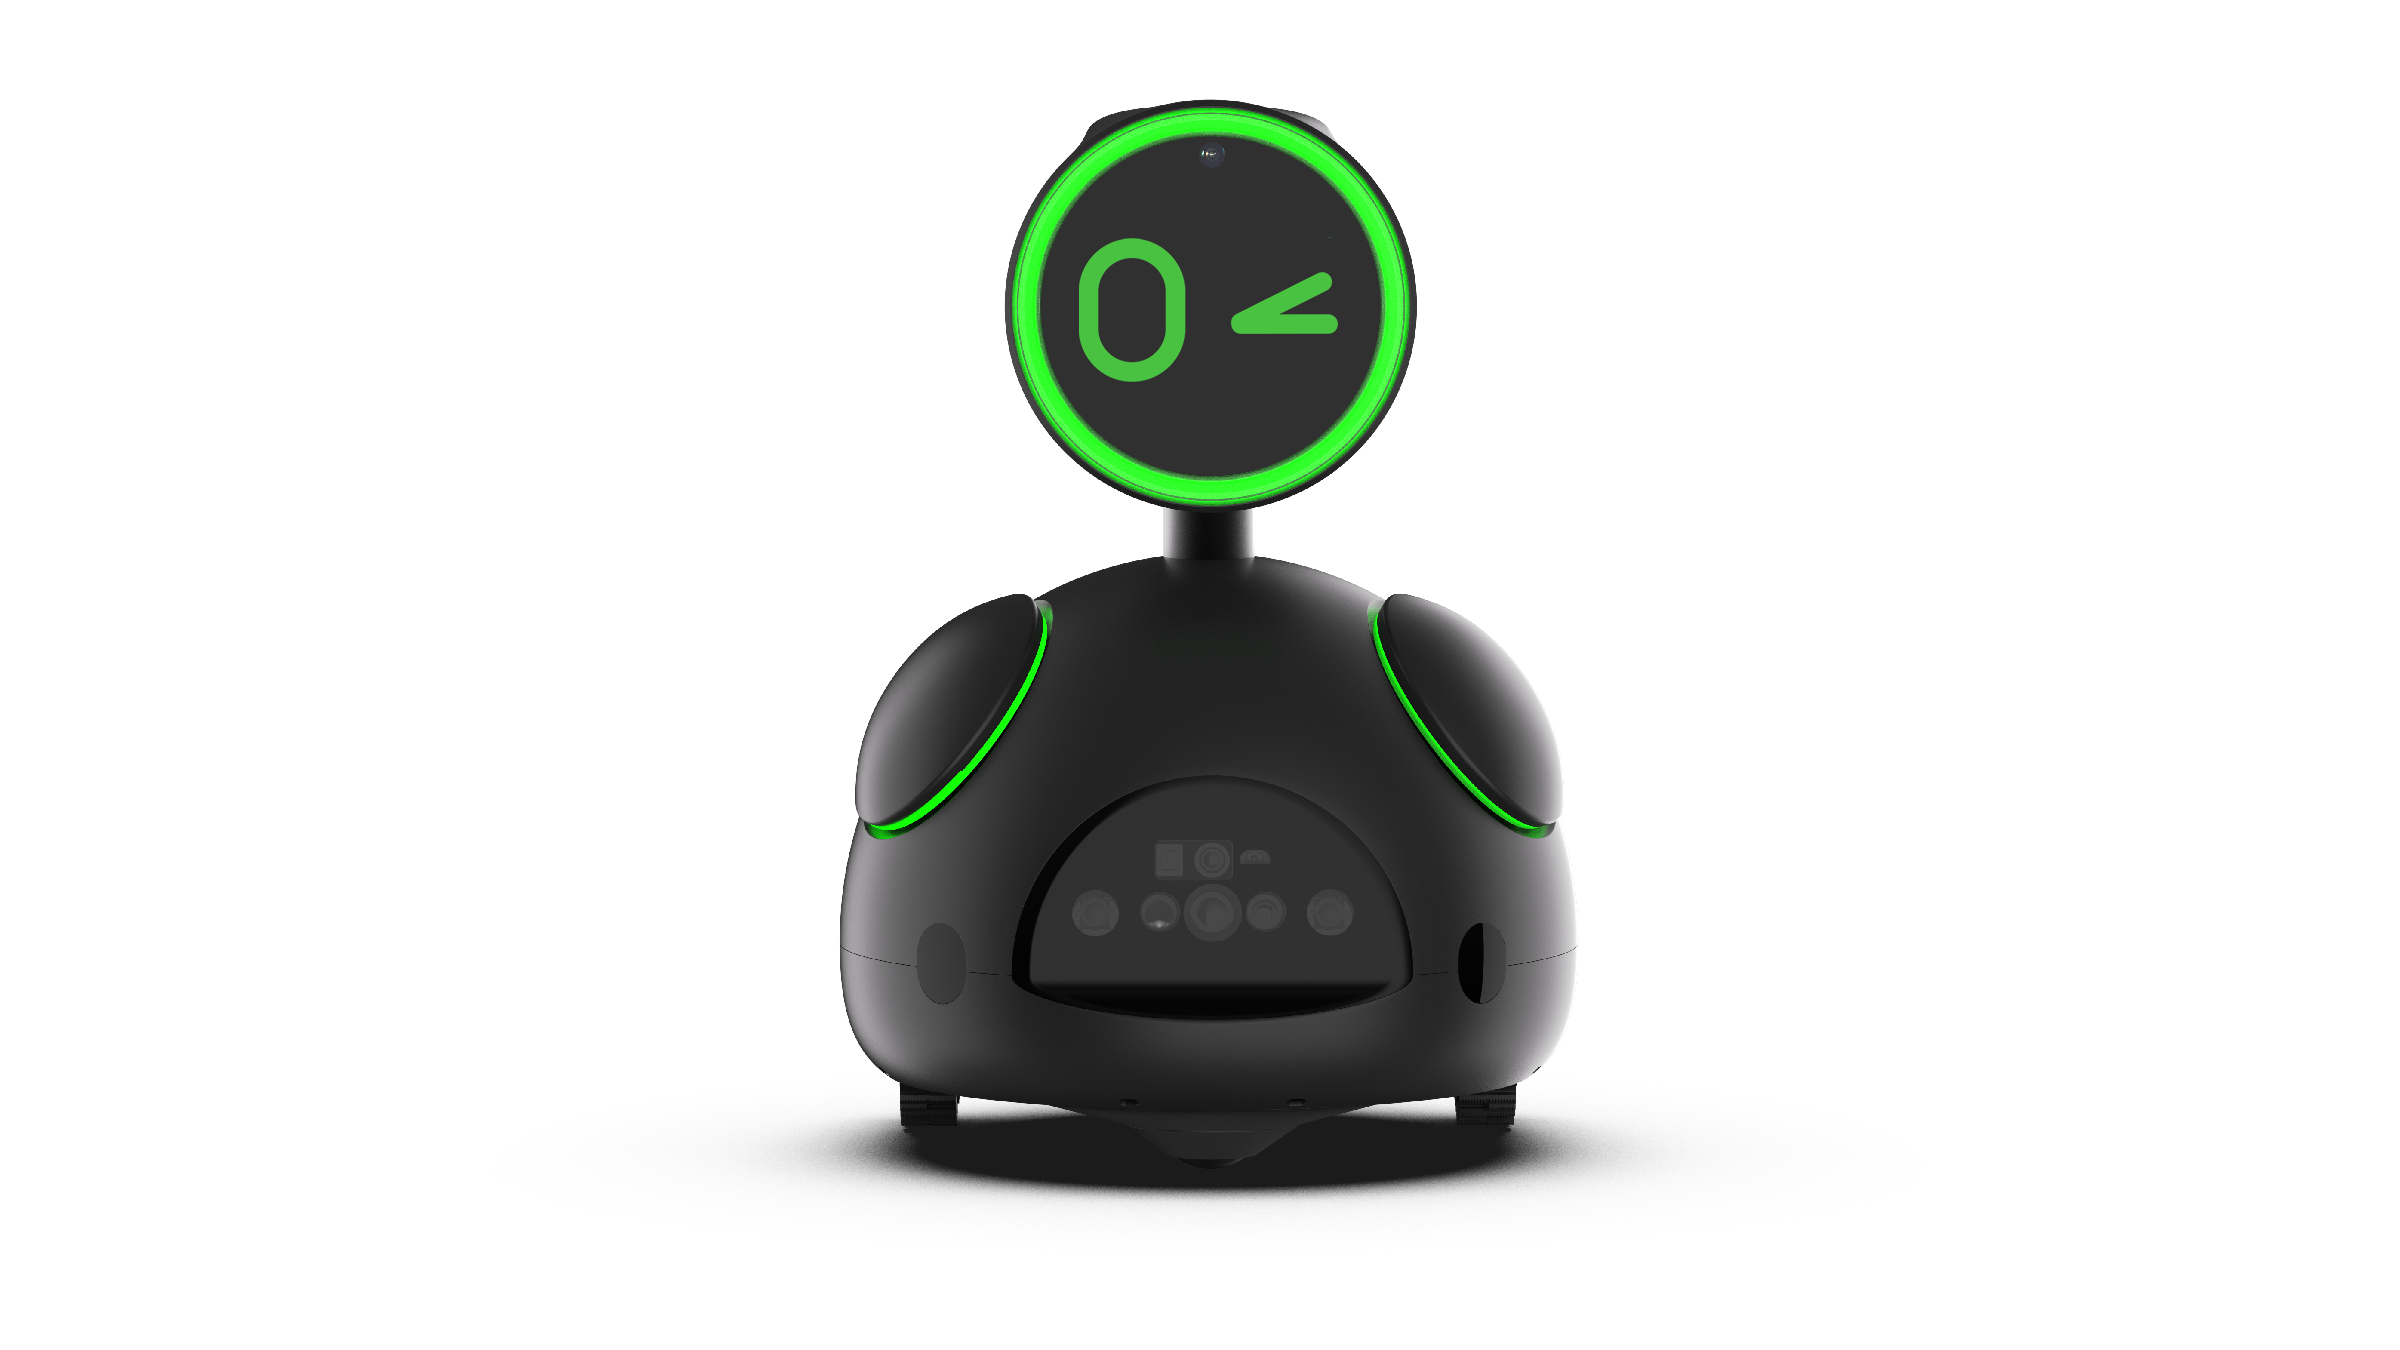
Company Briefs
LiveSupply Chain
Financials & Operations
News
No official updates yet — the chain engine will fill this timeline from verified official sources.